Unkyoung Won
Team lead
What if a robot arm could go anywhere? This is how DN Robotics began.
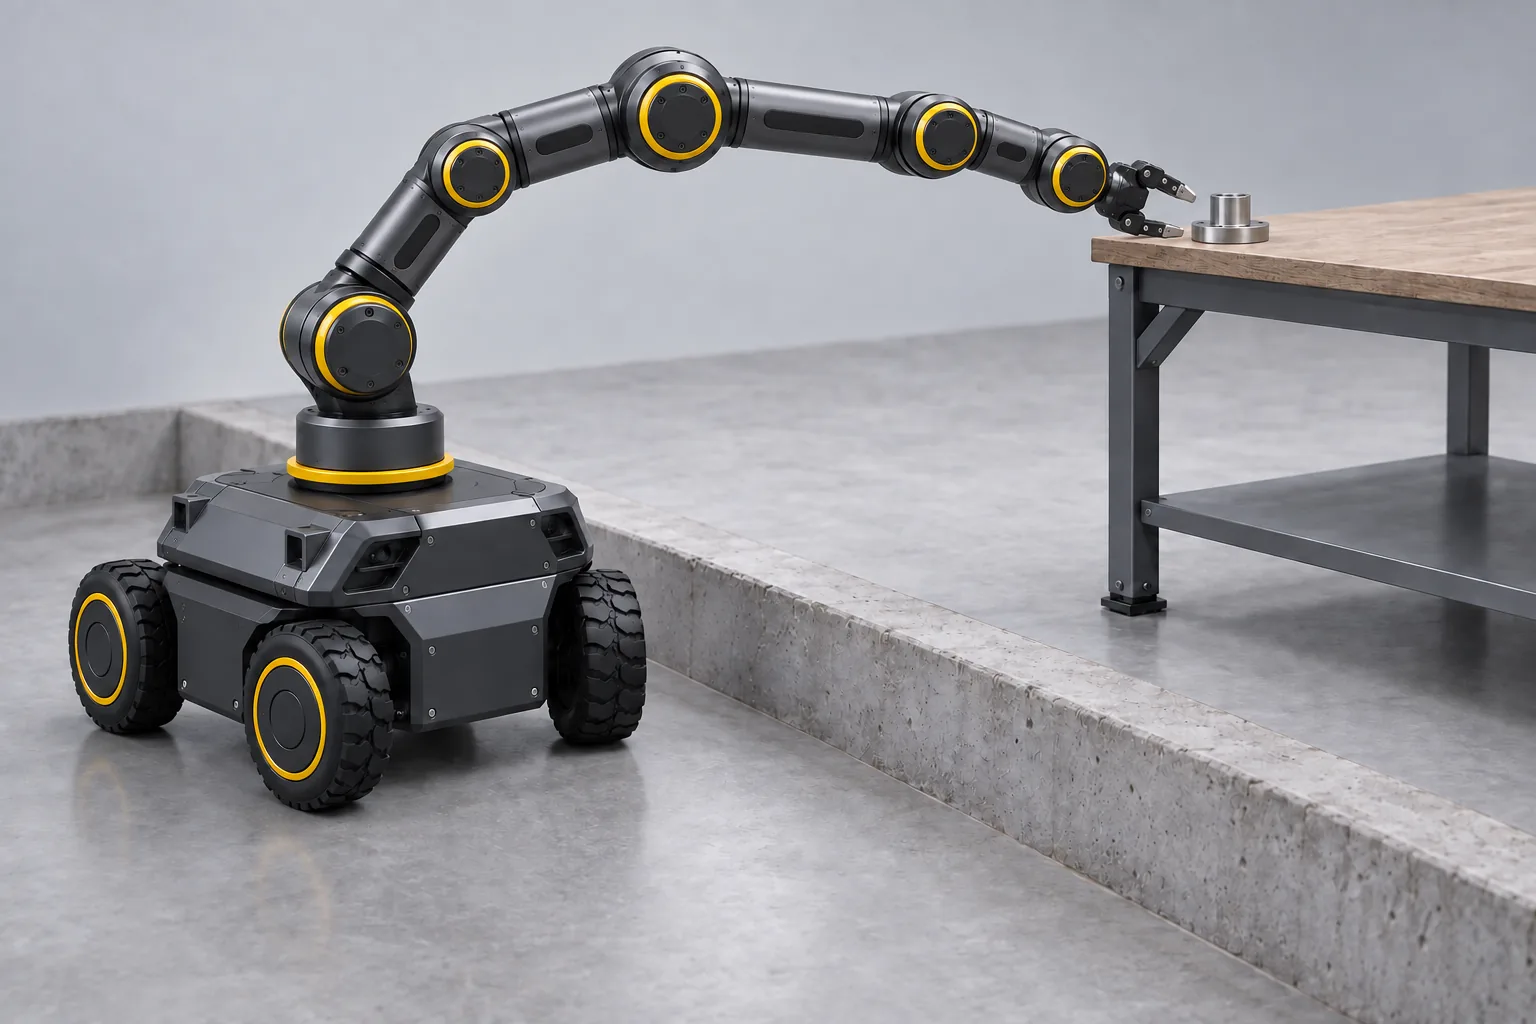
Four students studying robotics at the Department of Robot Engineering, Hanyang University ERICA, kept running into the same wall. The robot arms themselves were capable enough. But every time we tried to move an arm somewhere else, the floor got in the way.
A single threshold, a cable tray, a narrow aisle: when the mobile platform stopped, the arm riding on it stopped too. The arm could do plenty of work, but the floor decided where it could go.
That frustration, robot arms held back by the floor, is where DN Robotics began.
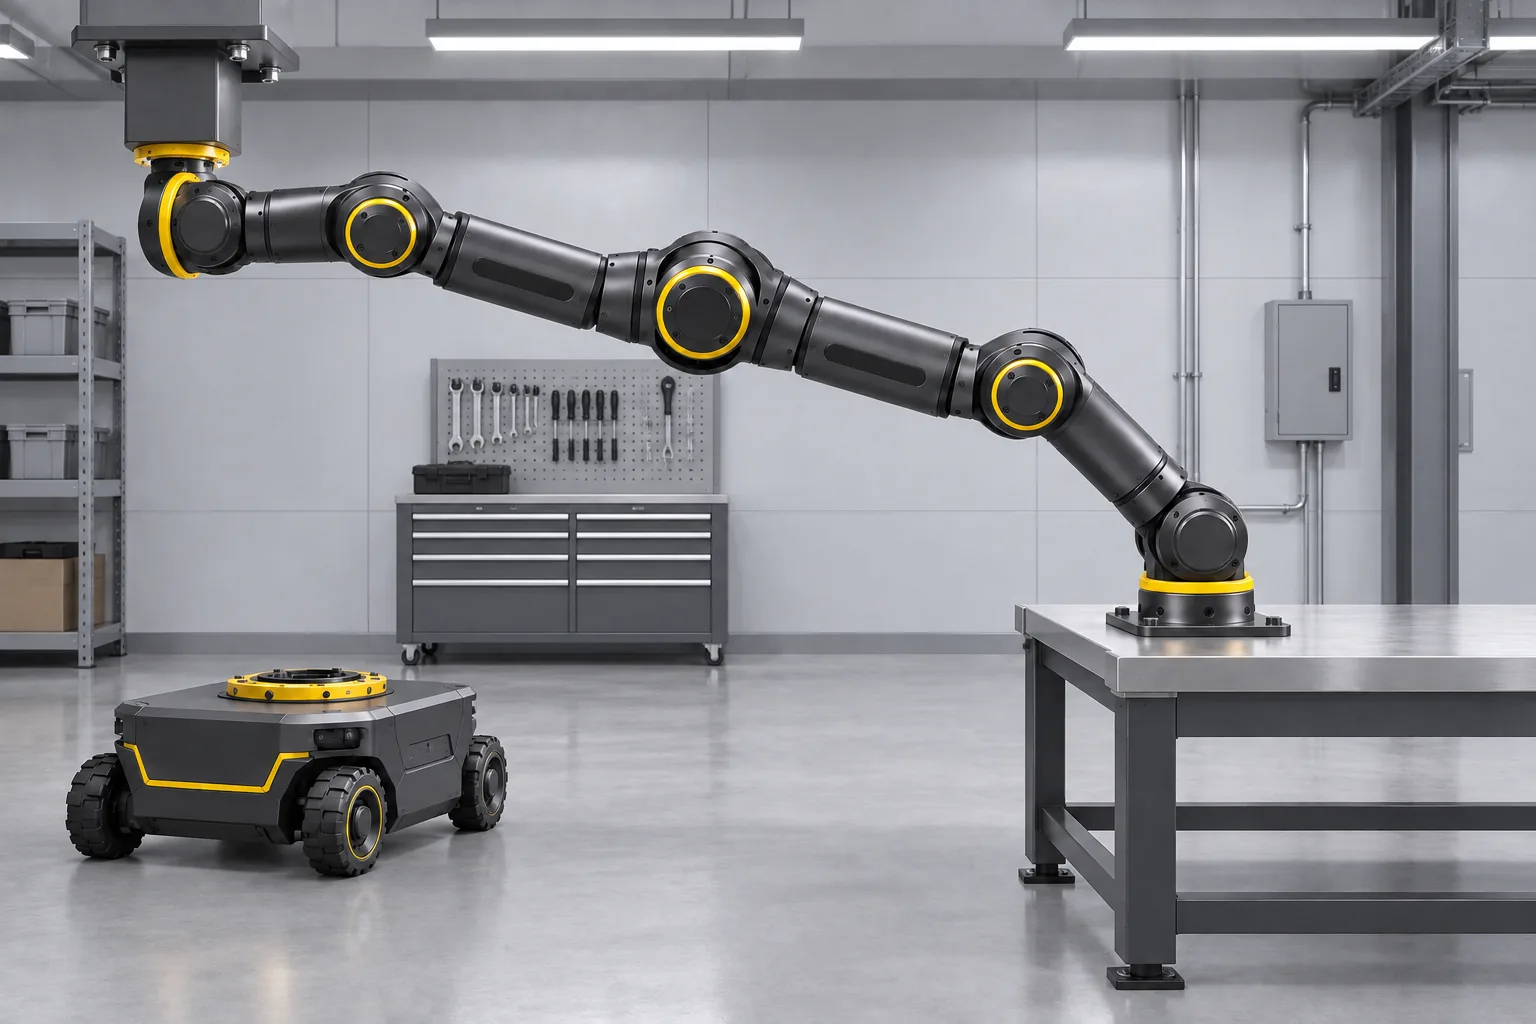
So we changed the question. Why does a robot arm always have to be bolted to one spot, or carried around on a wheeled platform?
The clue came from space. Canadarm2, the robotic arm on the International Space Station, works where there is no floor at all. Its two identical ends take turns gripping fixtures across the station, and the arm moves itself along like an inchworm.
Why couldn’t an arm on the ground move the same way? Put the same docking interface on both ends of the arm, and the same standard ports on ceilings, walls, floors, workbenches, AMRs and quadruped robots, and the arm can go anywhere by moving from port to port. If the floor is blocked, it simply grabs another port.
The arm was enough. The problem was its feet.
Instead of building a better arm, we decided to change where the arm stands. That one sentence is the starting point of everything we build.
DN comes from Docking and eNd effector.
How the end of the arm grips a port to anchor itself. A docked end becomes the foot the arm stands on.
The hand at the end of the arm that does the actual work, swapped for the right tool for each job.
Each end of our arm can be a foot that holds the body in place, or a hand that works with an interchangeable tool. The name carries that idea: both roles in a single end.
Recognized for our docking manipulator idea at DeepTechAudition, the on-campus startup competition at Hanyang University ERICA.
We passed the first-stage review and are preparing for the next stage.
Our goal is simple: instead of tearing up a workspace to bring robots in, let robots into any site with just a few ports.
We are working toward the day when standard docking ports sit throughout factories, labs and tight equipment rooms, and a single robot arm moves between them to get the work done.
Four of us studying robotics at the Department of Robot Engineering, Hanyang University ERICA.
Team lead
Software
Software
Hardware